I am an M.S. student in Computer Science at
Chongqing University, advised by Prof. Chao Chen. Before that, I
received my B.E. in Software Engineering from Chongqing University of Posts and Telecommunications.
My research focuses on World Action Models,
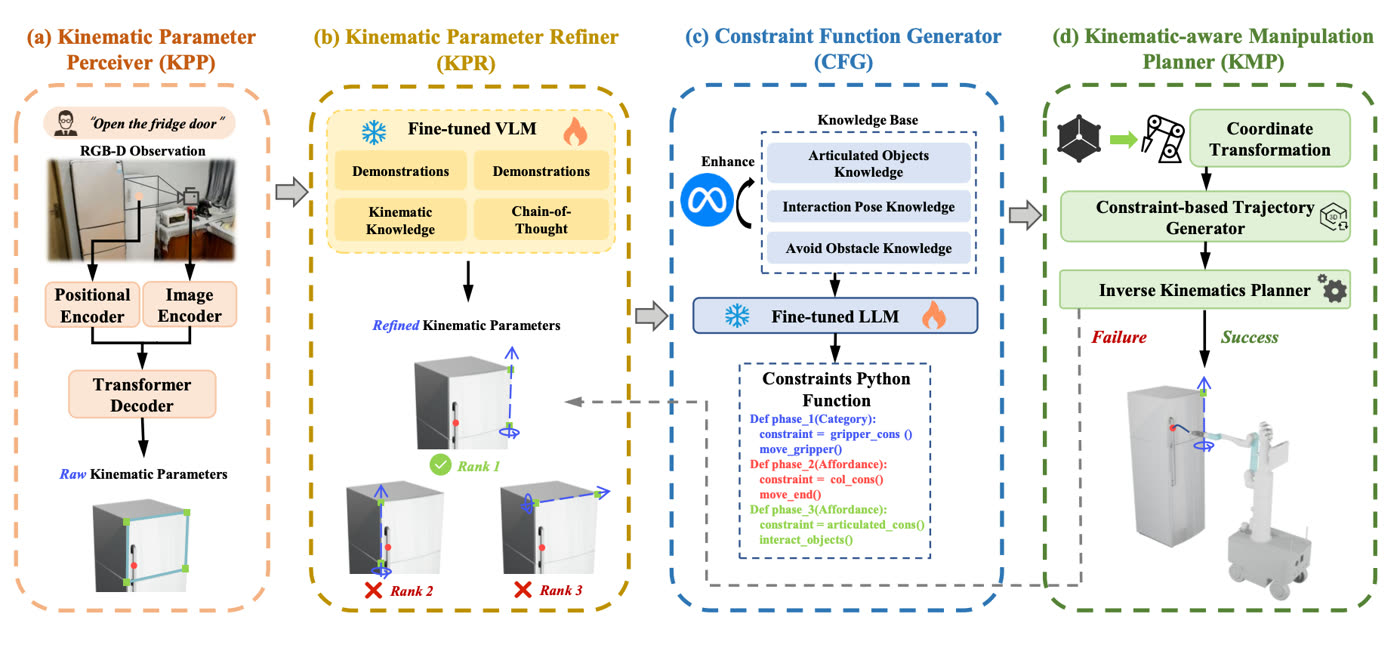
Generalizable Robot Manipulation, and 3D Affordance Grounding. I am
interested in building embodied agents that connect language and visual perception to robust, executable
actions in the physical world.
I am currently a Robot Learning Algorithm Intern at Astribot. Previously, I worked at the
vivo Central Research Institute Robotics Lab on vision-language-action policy deployment, robot
teleoperation, and simulation-to-real transfer.
🔥 News
2026.08: Joined Astribot as a Robot Learning Algorithm Intern.
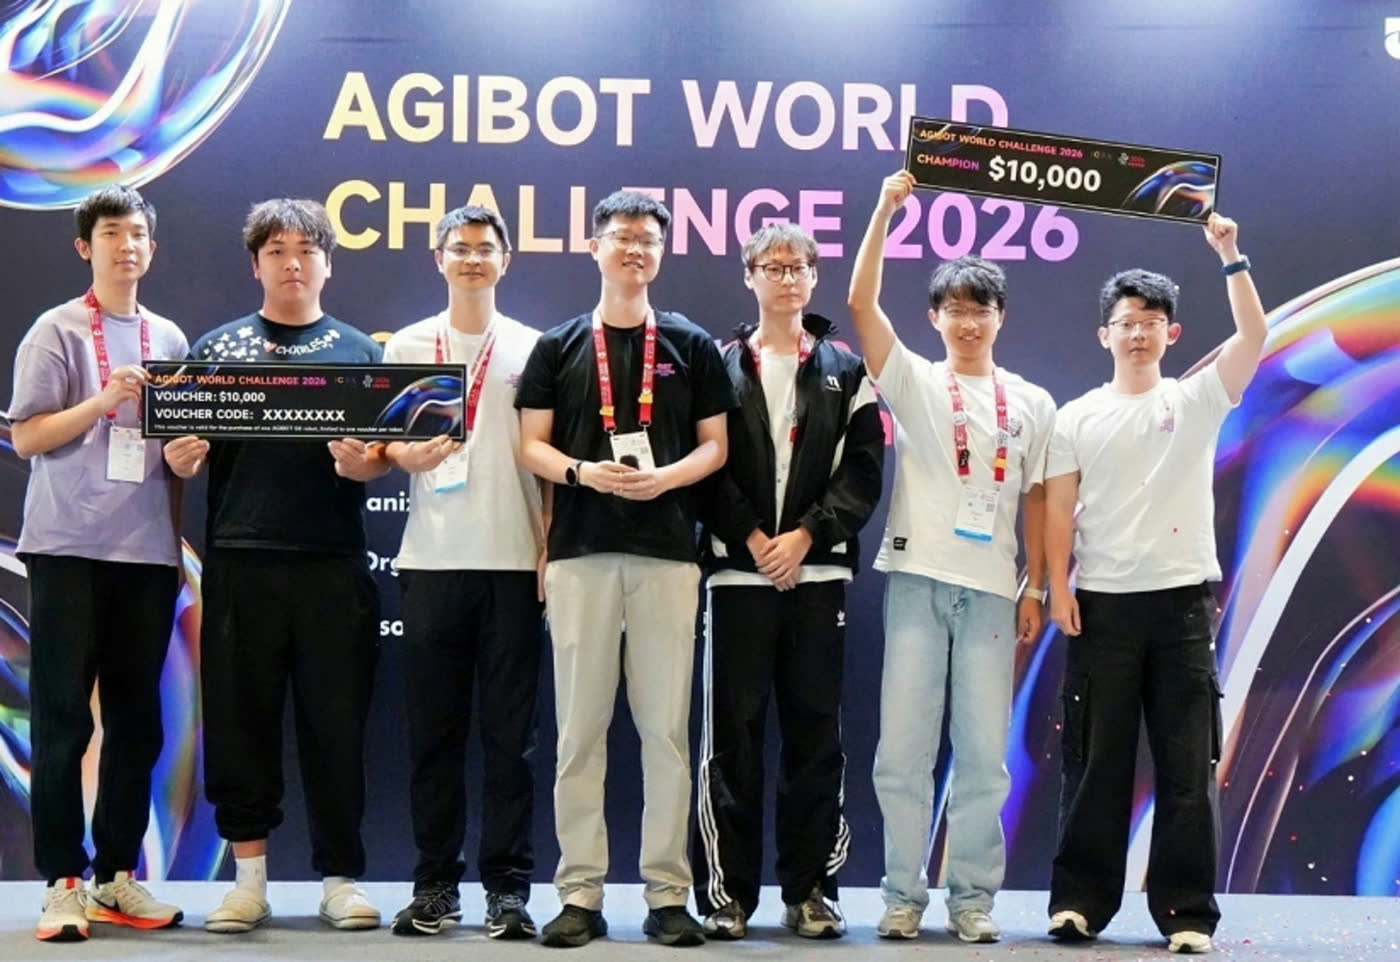
2026.06: Our PrismBot team won the Global Championship in the ICRA 2026 AgiBot World Challenge —
Reasoning to Action Track.
2026.05: GSAM was accepted to PPSN 2026.
2025.10: OVA-Fields was presented at ICCV 2025 in Honolulu, Hawaiʻi.
2025.09: Received the National Scholarship.
📘 Selected Publications
Under Review
ArcVLA: Action-Grounded Representation Calibration for Robust Vision-Language-Action Models
Heng Su, Y. Xie, H. Zheng, Z. Yan, X. Dai, M. Li, M. Xie, H. Yang, C. Chen
Aligns visual-language features with action representations through an action-anchored calibration
pathway.
Improves π₀.₅ from 86.7% to 93.7% on LIBERO-plus, and from 58.7% to 97.7% under sensor noise.
ICCV 2025
OVA-Fields: Weakly Supervised Open-Vocabulary Affordance Fields for Robot Operational Part Detection
Tingting Xu, Heng Su, Biao He, Aohua Tian, Jianing Guo
🏆 Research Highlight
ICRA 2026 · Global Champion
AgiBot World Challenge — Reasoning to Action Track
As a member of vivo Robotics Lab's PrismBot team, I developed long-horizon manipulation policies for
AgiBot Genie Sim 2.0 and the Genie G2 robot. I contributed task-aware trajectory optimization,
keyframe-sensitive objectives, and failure-prone subtask oversampling.
The team won the championship after competing with 526 teams from 27 countries and regions. We also
achieved Global 3rd Place in the RoboChallenge WBC Track.